Embodied Mobile Agents
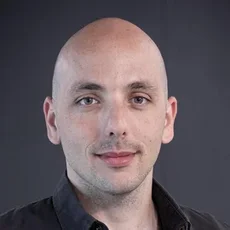
“Physical AI is already revolutionizing industries. The question is no longer whether a robot or an AI agent can do something, but how much it will cost and how efficiently it can learn new skills. We develop robots that learn from people and adapt to the real world, so that intelligence in the physical world becomes dependable enough to leave the lab.”
Expertise and Services
Expertise
- Reinforcement learning, adaptive control, and mobile robot learning
- Foundation models in mobile robotics (e.g., vision-language-action models and natural language interfaces)
- Learning from demonstration and sim-to-real transfer
- Human-centric and agentic AI for intuitive human–robot collaboration
The Embodied Mobile Agents group focuses on advancing mobile robot learning and embodied intelligence, with an emphasis on human-centric and agentic AI systems. Our expertise spans reinforcement learning, learning from demonstration, and sim-to-real transfer for quadrupeds, humanoids, and mobile manipulators.
We develop Vision-Language-Action (VLA) models and natural language task interfaces that enable intuitive collaboration between humans and robots. Applications range from rehabilitation robotics and assistive mobility to construction training and digital twinning, and to safe and adaptive humanoid systems in healthcare workflows. By combining cutting-edge machine learning with applied, interdisciplinary research, we aim to create embodied AI that is intuitive, adaptive, and socially relevant.
Services
- Insight: keynotes, trainings
- AI consultancy: workshops, expert support, advise, technology assessment
- Research and development: small to large-scale collaborative projects, third party-funded research, student projects, commercially applicable prototypes
Additional Information
Beyond our research projects:
- Focus areas: Humanoid and semi-humanoid robots, flexible automation solutions, and data-efficient Physical AI algorithms
- Labs and robots: We develop and test on quadrupeds, humanoids and mobile manipulators in Winterthur and lead the Winterthur Robotics & Physical AI Hub.
- Teaching: We lead the new CAS Physical AI & Robotics, bringing embodied AI to practicing engineers, in addition to defining new curricula across the Bachelor and Master programs.
- European networks: We chair a newly approved COST Action building a European network on Agentic Physical AI with partners from eight countries.
- From research to practice: Our spin-off Binabik AI develops agentic software for wheeled humanoid robots, working on industrial automation solutions that are being deployed today.
- Robots in public: We take our robots out of the lab regularly, from the World Economic Forum in Davos and the Swiss Robotics Day to VivaTech in Paris.
Team
Head of Research Group

Projects
-
Humanoid Robots for Cleaning and Sterilization of Medical Equipment (HERCULES)
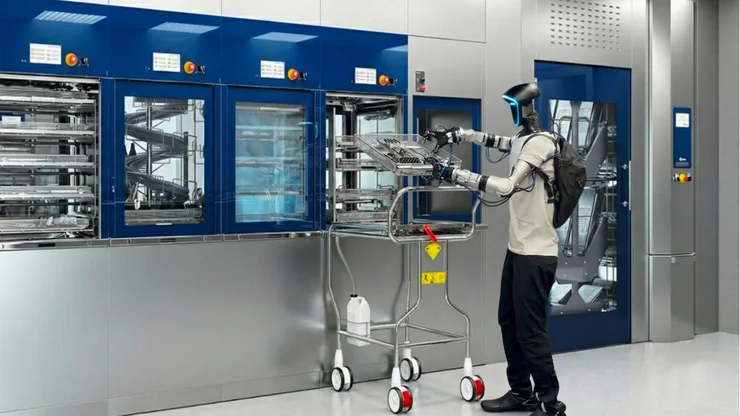
This project develops AI-driven humanoid robot automation for hospital sterilization departments (CSSDs). Combining robotic foundation models with environment-aware whole-body control, we enable autonomous handling of surgical instruments and sterile containers, validated with pilots in hospitals.
current, 05/2026 - 04/2028
-
Explainable RL and Agentic Physical AI for Assistive Mobile Manipulation (CareBot)
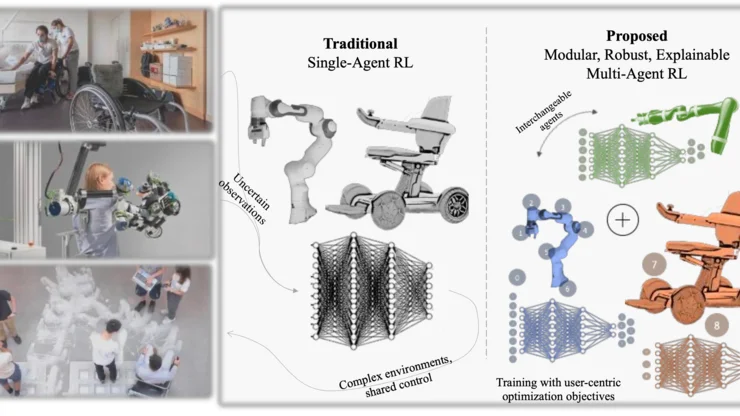
Human-Centric and Explainable Robot Learning for Mobile Manipulation: Vision-Language-Action models and Reinforcement Learning assistive mobility and humanoids in healthcare, with Swiss industry and academic partners
current, 04/2026 - 03/2028
-
Avatar Demonstrator: VR Control for Humanoid Robots
AVATAR lets visitors control a humanoid robot in VR, seeing through its eyes and manipulating objects via intuitive, body-based teleoperation.
expired, 01/2026 - 07/2026
-
Talking Bots: Interactive Voice Interface for Humanoid Robots in Networking Events
Talking Bots: Interactive voice interface for humanoid robots in networking events with context-aware conversational capabilities.
expired, 10/2025 - 12/2025
-
Robot Assistant with Physical Agentic AI
Humanoid Robot Assistant with Physical Agetic AI: Towards general robotics for mobile manipulation with adaptability across tasks and environments.
expired, 10/2025 - 03/2026
Publications
-
Salimpour, Sahar; Fu, Lei; Rachwał, Kajetan; Bertrand, Pascal; O'Sullivan, Kevin; Jakob, Robert; Keramat, Farhad; Militano, Leonardo; Toffetti Carughi, Giovanni; Edelman, Harry; Peña Queralta, Jorge,
2025.
arXiv.
Available from: https://doi.org/10.21256/zhaw-35983
-
Salimpour, Sahar; Peña-Queralta, Jorge; Paez-Granados, Diego; Heikkonen, Jukka; Westerlund, Tomi,
2025.
Sim-to-real reinforcement learning for local mobile robot navigation in dynamic environments[paper].
In:
2025 European Conference on Mobile Robots (ECMR).
European Conference on Mobile Robots (ECMR), Padova, Italy, 2-5 September 2025.
IEEE.