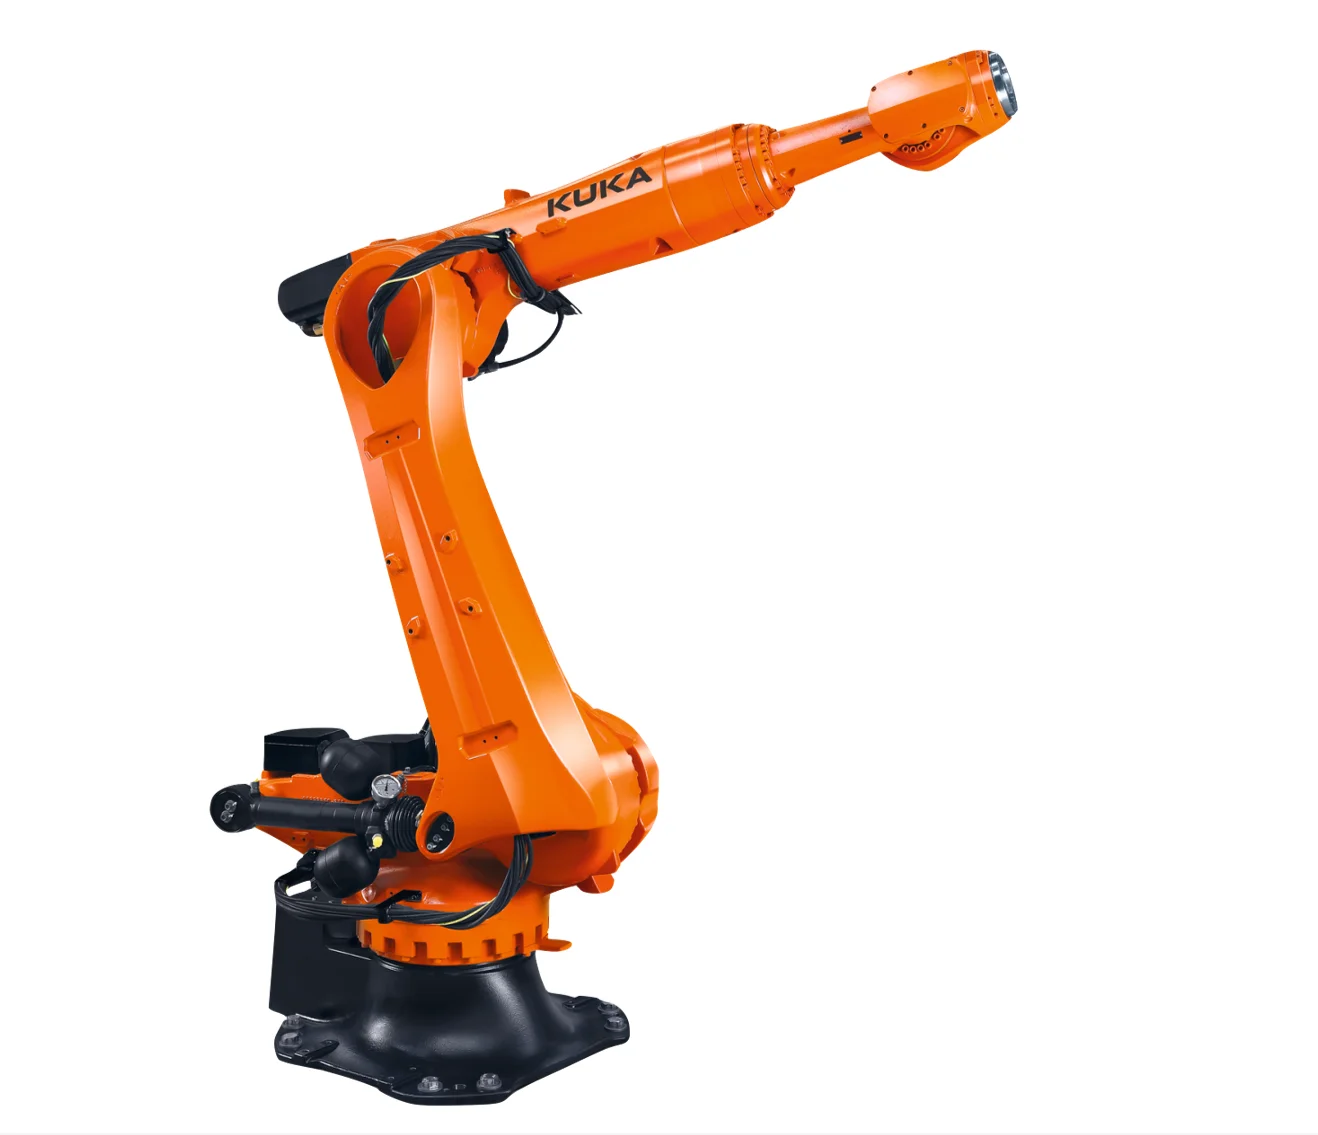
KUKA Quantec KR150 R2700
6-axis research Robot with ATI Omega160 IP60 Force-Torque Sensor
Technical Specifications:
Robot
- Maximum payload: 150 kg
- Reach: 2701 mm
- Repeatability: 0.05 mm
- Test modes: (Cyclic) motion sequences, position search
- Motion control: Position-controlled and/or force-controlled motion
Force and Torque Sensor
- Force ranges (±):
- Fx: ±1'500 N
- Fy: ±1'500 N
- Fz: ±3'750 N
- Torque ranges (±):
- Tx: ±240 Nm
- Ty: ±240 Nm
- Tz: ±240 Nm
- Measurement uncertainty:
- Fx: 1.00 %
- Fy: 1.00 %
- Fz: 1.00 %
- Tx: 1.00 %
- Ty: 1.25 %
- Tz: 1.25 %
- Number of available systems: 1
- Interchangeable adapter fixtures allow various custom mounting solutions to be attached to the robot arm.
- The robot can be operated in user-defined coordinate systems, enabling flexible and application-specific motion control.
- The system is ideally suited for biomechanical investigations involving articulated joints under physiological motion. It is also suitable for automated testing, complex multi-axis loading scenarios, and the validation of simulation models.